RoboTUM Humanoid Robot
Mechanical design, actuators and joints for a student-built humanoid
Hardware development for a humanoid robot at RoboTUM, focused on mechanical design, actuator and joint development, and experimental validation.
- Role
- Senior Member · Co-Lead, Hardware Department
- Organisation
- RoboTUM — student robotics organisation, Technical University of Munich
- Period
- Oct 2025 – present
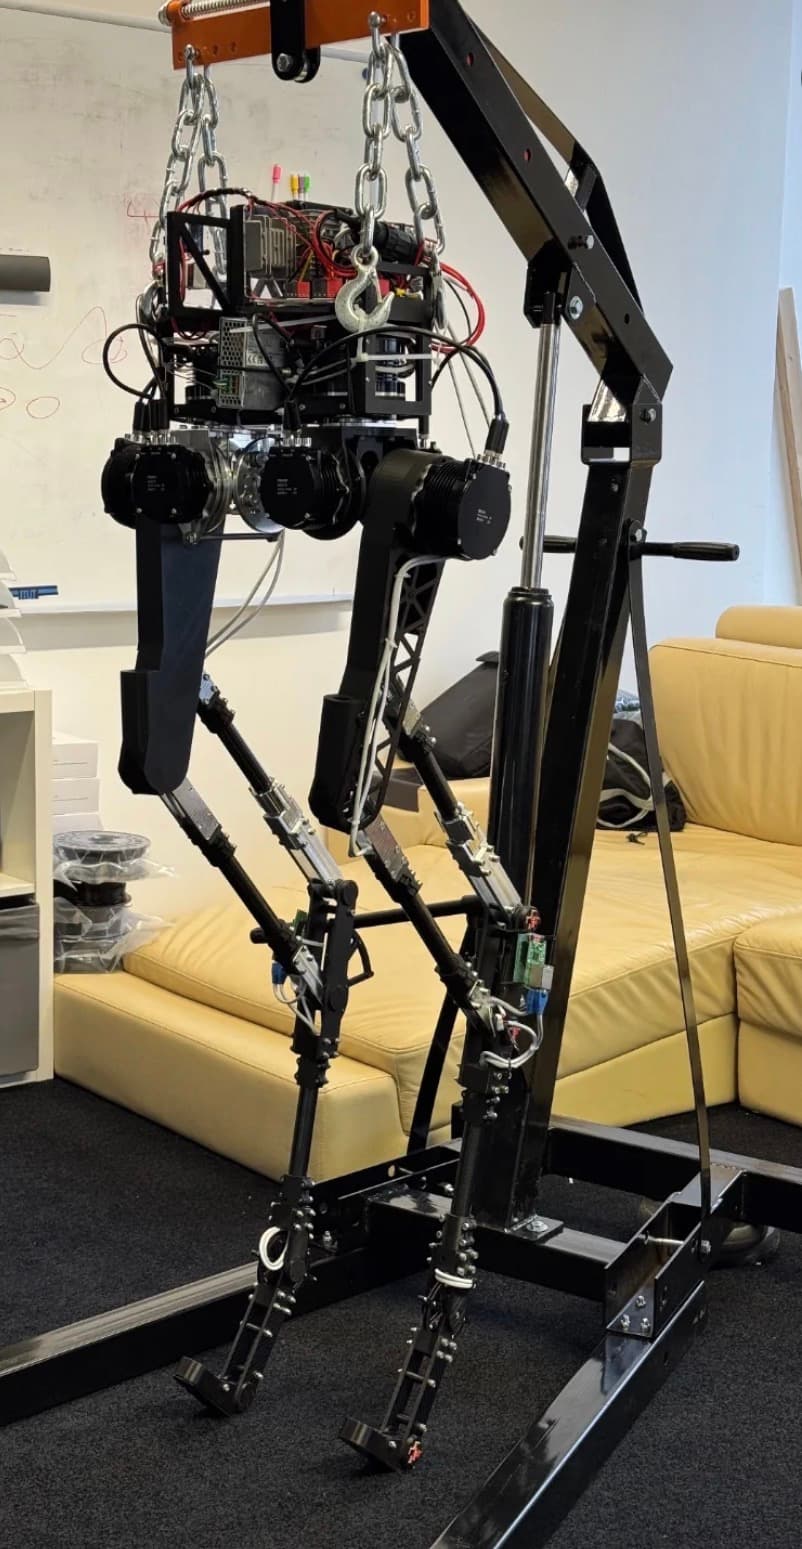
Overview
RoboTUM is a student robotics organisation at the Technical University of Munich developing a high-performance humanoid robot. I joined the humanoid project in October 2025 and became a Senior Member and Co-Lead of the Hardware Department in March 2026.
The robot is built by a large team spanning mechanics, electronics, control and learning. My own work sits on the hardware side: the physical robot, and the development and validation of its mechanical and actuator systems.
My Contribution
- Contributing to the mechanical development of the humanoid robot.
- Working on actuator and joint concepts.
- Designing mechanical test setups for actuator and joint validation.
- Supporting prototype development and hardware iteration.
- Evaluating hardware concepts with the goal of improving performance, robustness and integration.
- Coordinating and contributing to hardware development as Co-Lead of the Hardware Department.
Engineering & Design
A humanoid requires close interaction between mechanical design, actuator selection, electronics, control and the overall robot architecture. Joint and actuator decisions therefore cannot be made in isolation — they have to hold up against mass distribution, packaging, structural stiffness and what the control side needs from the joint.
Testing & Validation
A hardware concept is only as good as the measurement behind it, so part of my work is building the setups that produce those measurements. I design mechanical test rigs for validating actuators and joints, and use them to evaluate concepts before they are committed to the full robot.
Broader Project Context
Development at RoboTUM also covers simulation and learning-based locomotion, which is the work of other teams within the project. My own contribution is on the robot's hardware: mechanical design, actuators, joints, test setups and validation.
Media
Technical areas
- Humanoid Robotics
- Mechanical Design
- Actuator & Joint Development
- Hardware Prototyping
- Mechanical Test Setups
- Experimental Validation
- SolidWorks