Skip to content

M.Sc. Robotics, Systems and Control · ETH Zurich

Moritz Kirchleitner

Mechanical engineer building robotic systems at the intersection of mechanism design, actuation and control.

My background is in mechanical engineering with a focus on robotic hardware, dexterous manipulation, actuator design and prototyping. I am particularly interested in robotic systems with many degrees of freedom, and I am currently extending my work toward control, software and learning-based robotics.

Antagonistic tendon-driven finger prototypes — Bachelor's thesis, TUM

Selected Projects

Engineering projects

01 · Sep 2025 – Feb 2026

Variable-Stiffness Robotic Finger

Antagonistic tendon-driven actuation for dexterous robotic hands

An antagonistic tendon-driven robotic finger with a directly integrated elastic element — mechanical design, 3D-printed prototypes, two instrumented test benches and the control and measurement software used to characterise them.

Professorship for Healthcare and Rehabilitation Robotics, Technical University of Munich

  • Tendon-Driven Actuation
  • Variable Stiffness
  • Mechanical Design
  • Rolling-Contact Joints
  • Prototyping
  • Test-Bench Design
  • Control Software
  • Optical Measurement
  • MATLAB
  • SolidWorks
Read the case study
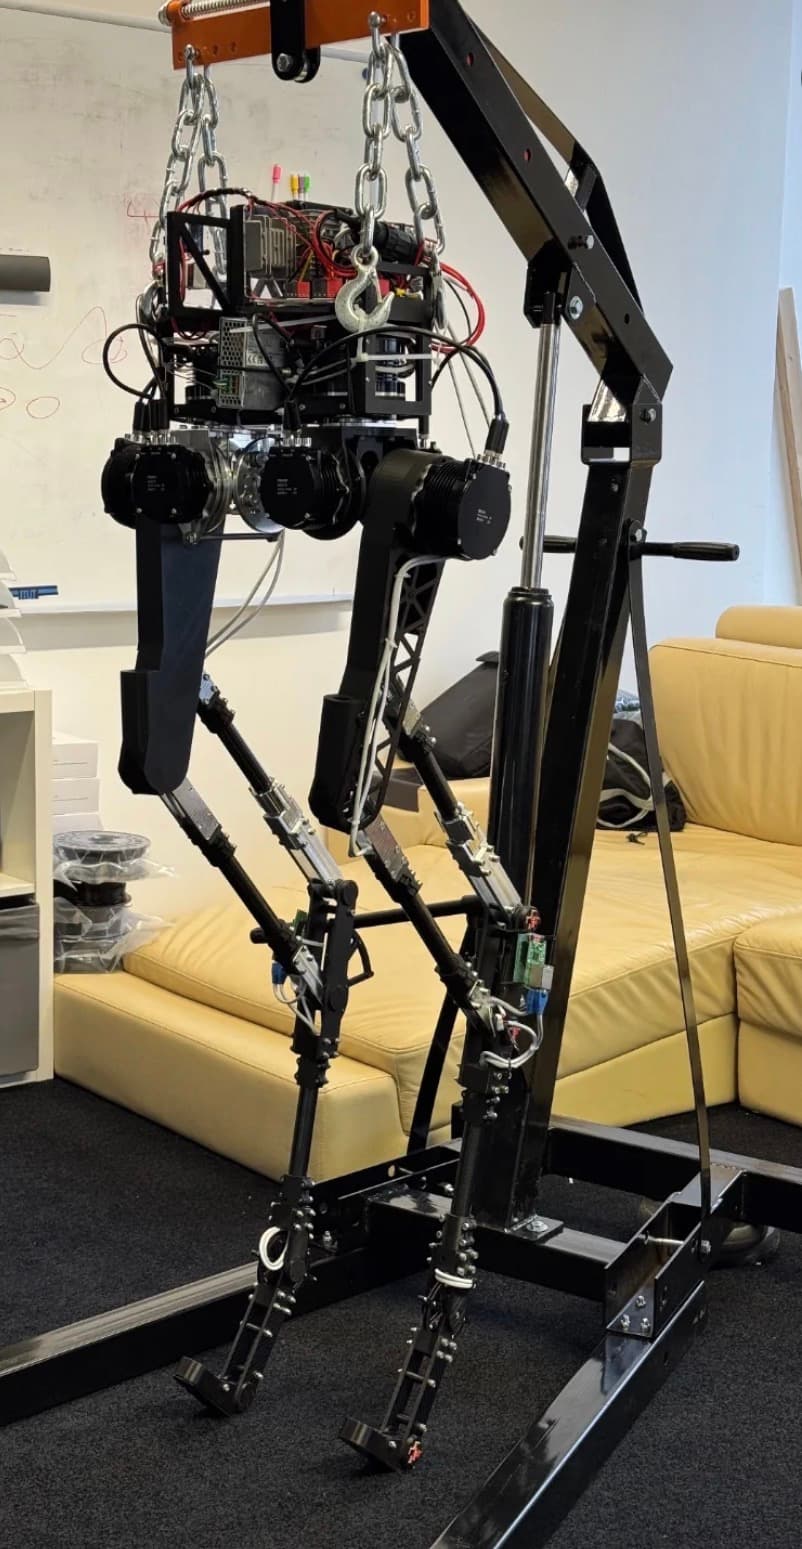
The assembled RoboTUM humanoid suspended in a test gantry, showing the hip actuators and the linkage-driven knee and ankle joints.

02 · Oct 2025 – present

RoboTUM Humanoid Robot

Mechanical design, actuators and joints for a student-built humanoid

Hardware development for a humanoid robot at RoboTUM, focused on mechanical design, actuator and joint development, and experimental validation.

RoboTUM — student robotics organisation, Technical University of Munich

  • Humanoid Robotics
  • Mechanical Design
  • Actuator & Joint Development
  • Hardware Prototyping
  • Mechanical Test Setups
  • Experimental Validation
  • SolidWorks
Read the case study

03 · Jan 2025 – May 2025

Self-Balancing Robot

A BB-8-inspired ball-balancing robot: modelling, PD control and hardware

Modelling, simulation and control of a BB-8-inspired robot balancing on a ball — including PD controller development in MATLAB/Simulink and implementation on a physical prototype.

Georgia Institute of Technology

  • Dynamic Modelling
  • PD Control
  • MATLAB
  • Simulink
  • Simulation
  • Physical Prototyping
  • Controller Tuning
Read the case study

Experience

Education & experience

Education

  • ETH Zurich

    M.Sc. Robotics, Systems and Control

    • Focus on robotic manipulation, control and learning-based methods.

    Sep 2026 – present

    Zurich, Switzerland

  • Technical University of Munich

    B.Sc. Mechanical Engineering

    • Final grade 1.4 (1.0 = best).
    • Top 2% of the Mechanical Engineering Department.

    Oct 2022 – Mar 2026

    Munich, Germany

  • Georgia Institute of Technology

    Exchange Semester

    • Focus on control engineering, robotic systems and renewable energy systems.
    • GPA 4.0 / 4.0.

    Jan 2025 – May 2025

    Atlanta, GA, USA

Work Experience

  • Agile Robots

    Working Student

    • Actuator design and robotic hardware development.
    • Mechanical development work on tendon-driven robotic hands.
    • Testing of robotic hands.

    May 2024 – Dec 2024 · Dec 2025 – Sep 2026

    Munich, Germany

  • Heidenhain AG

    Service Technician Intern

    • Maintenance and setup of roll bending and laser welding machines.
    • Quality control on metal ring production using precision gauges.

    Jul 2022 – Sep 2022 · Mar 2023 – May 2023

    Traunreut, Germany

Engagement

  • RoboTUM

    Senior Member · Co-Lead, Hardware Department

    • Hardware development for a high-performance humanoid robot; Co-Lead of the Hardware Department since March 2026.

    Oct 2025 – present

    Munich, Germany

  • EyeVoices

    Head of Hardware

    • Development of an assistive communication platform for people with severe paralysis.

    Sep 2025 – present

    Munich, Germany

  • Ferienakademie (TUM, FAU & University of Stuttgart)

    Scholarship

    • Two-week interdisciplinary project on environmental sustainability with students from different technical backgrounds.

    Sep 2024 – Oct 2024

    South Tyrol, Italy

About

Background

I come from mechanical engineering, and what drew me in was always mechanisms with many degrees of freedom — the question of how a lot of controlled motion can be packed into very little space.

That interest led me to robotic hands, actuators and humanoid systems. Dexterous robotic systems are interesting precisely because they combine mechanical complexity with a hard engineering constraint: the result still has to be compact, robust, controllable, and able to interact with the physical world.

My work so far has therefore been concentrated on mechanisms, robotic hardware, actuation, prototyping and testing — designing parts, building them, and then finding out on a test bench how they actually behave.

At ETH Zurich I am now extending that background toward control, software and learning-based robotics, so that I can work on the full system rather than only its mechanics.

Skills & Tools

Programming
C · Python · MATLAB
Mechanical & CAD
SolidWorks · Fusion 360 · CAM · 3D printing / prototyping
Tools
Git · LaTeX
Languages
German (native) · English (fluent)

Contact

Get in touch

I am happy to talk about robotic hardware, actuation and control — whether that is a research position, an internship or a thesis topic.

Elsewhere