Projects
Engineering projects
Sep 2025 – Feb 2026
Variable-Stiffness Robotic Finger
Antagonistic tendon-driven actuation for dexterous robotic hands
An antagonistic tendon-driven robotic finger with a directly integrated elastic element — mechanical design, 3D-printed prototypes, two instrumented test benches and the control and measurement software used to characterise them.
- Tendon-Driven Actuation
- Variable Stiffness
- Mechanical Design
- Rolling-Contact Joints
Oct 2025 – present
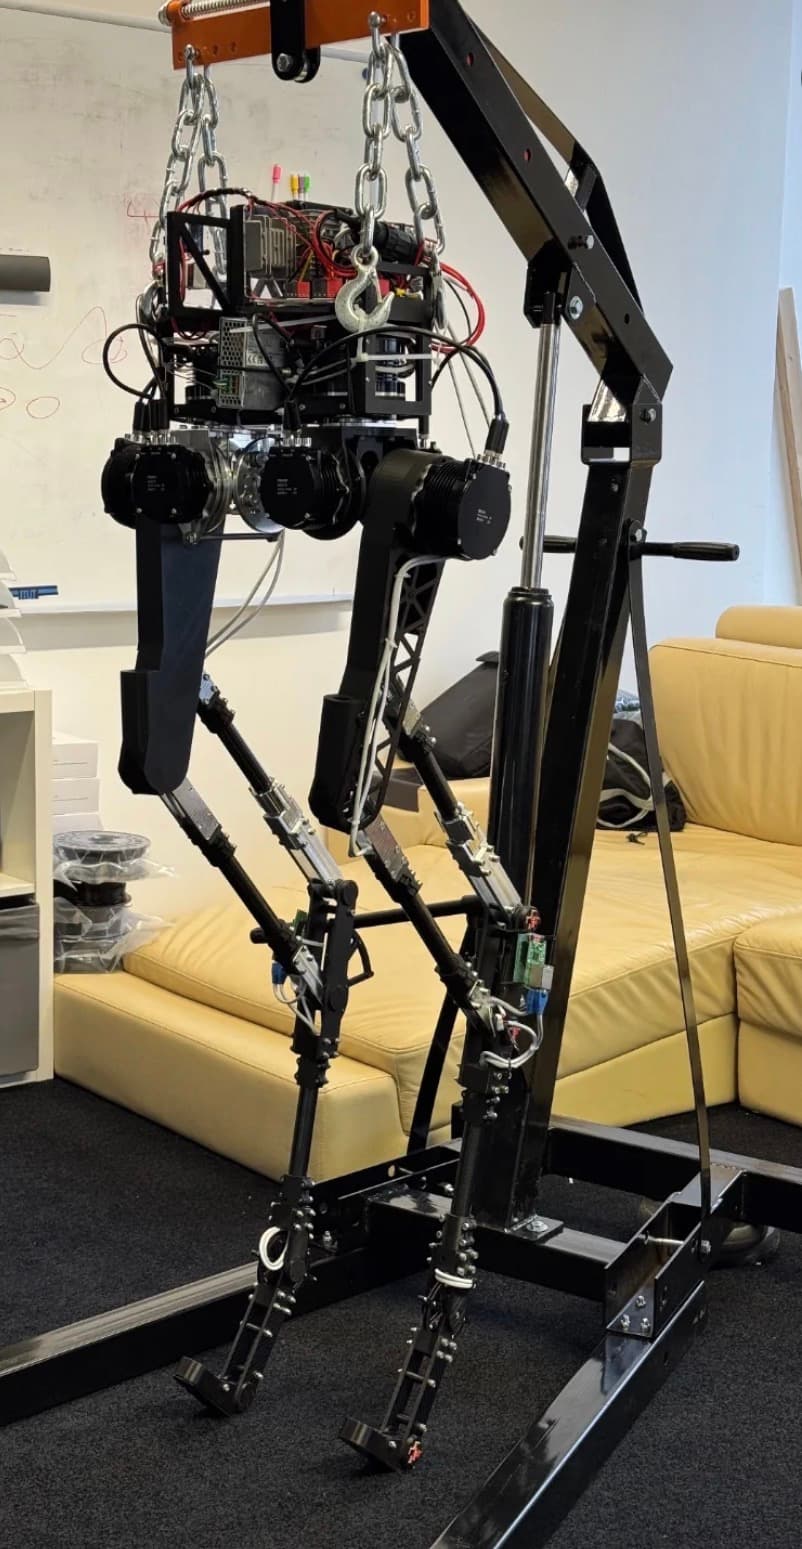
RoboTUM Humanoid Robot
Mechanical design, actuators and joints for a student-built humanoid
Hardware development for a humanoid robot at RoboTUM, focused on mechanical design, actuator and joint development, and experimental validation.
- Humanoid Robotics
- Mechanical Design
- Actuator & Joint Development
- Hardware Prototyping
Jan 2025 – May 2025
Self-Balancing Robot
A BB-8-inspired ball-balancing robot: modelling, PD control and hardware
Modelling, simulation and control of a BB-8-inspired robot balancing on a ball — including PD controller development in MATLAB/Simulink and implementation on a physical prototype.
- Dynamic Modelling
- PD Control
- MATLAB
- Simulink